
Introduced in response to persistent vehicle and pedestrian crash fatalities, FMVSS No. 127 (49 CFR §571.127) establishes new performance requirements for automatic emergency braking (AEB), pedestrian automatic emergency braking (PAEB), and forward collision warning (FCW) on passenger cars and light vehicles.
The standard raises the performance expectations for AEB, including higher-speed operation, pedestrian scenarios, daytime and nighttime testing, and collision-avoidance requirements.
AEB begins with understanding what is ahead. The system must identify a potential hazard, assess the risk, and respond with enough time to avoid a collision. As vehicle speed increases or visibility decreases, the available response time shrinks. Pedestrian movement, partial obstruction, and changing lighting conditions add further uncertainty.
Modern AEB systems can use multiple sensing technologies to understand the environment around the vehicle. Each provides a different type of information to the perception system.
01

Provides visual detail for object recognition and classification.
02

Provides accurate distance and relative velocity information.
03

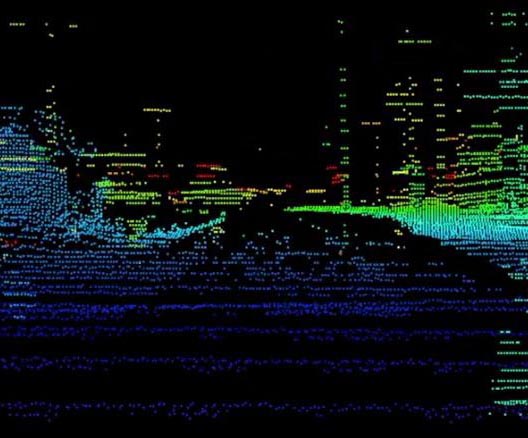
Provides detailed depth and spatial information.
Together, these sensing modalities provide a more complete view of the driving environment. Their strengths are complementary — but so are their limitations →
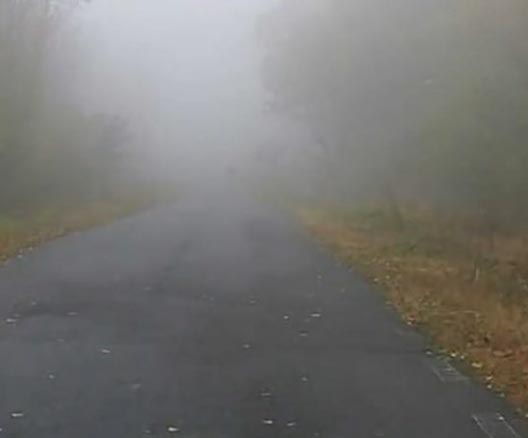
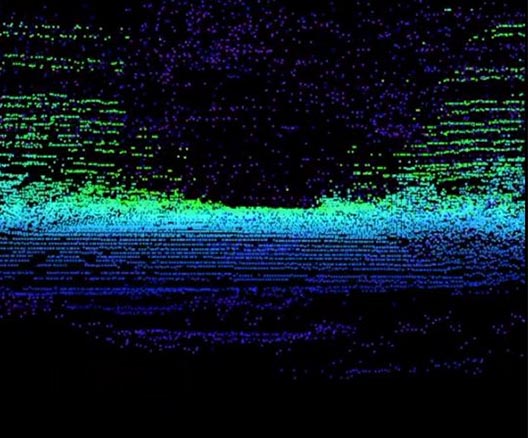
Lighting, weather, object properties, and the surrounding environment all affect the quality of information available to the perception system. Incomplete, degraded, or ambiguous information can delay detection, localization, or classification, reducing the time available to avoid a collision.
Less reliable information can mean less time to make the right decision.
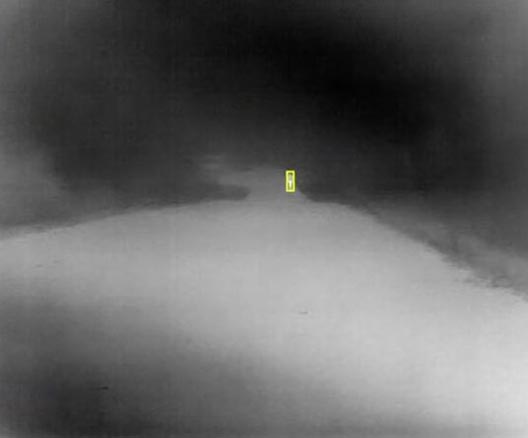
Infrared sensors detect emitted thermal energy (heat) rather than relying on visible light. Pedestrians, vehicles, and animals retain contrast in darkness and visually low-contrast conditions, giving the perception system an additional source of information. For FMVSS 127, that directly supports pedestrian detection in nighttime and low-light scenarios where visible-light perception is naturally reduced.
And as safety requirements continue to evolve, those conditions extend well beyond the test track.
FMVSS 127 establishes a defined performance baseline. Real roads introduce far more variation:
Infrared adds a distinct perception channel based on thermal contrast rather than visible appearance. In darkness, glare, low-contrast scenes, and adverse weather, infrared can retain critical object information when visible-light perception is degraded.
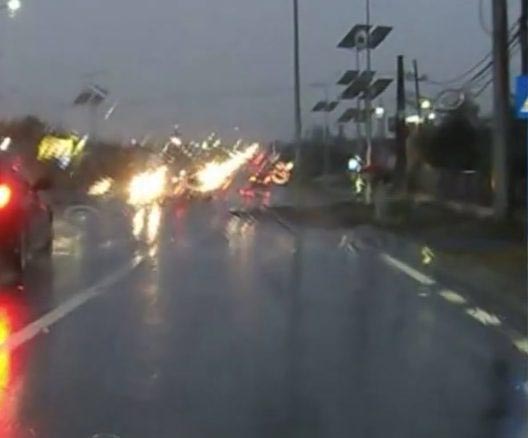
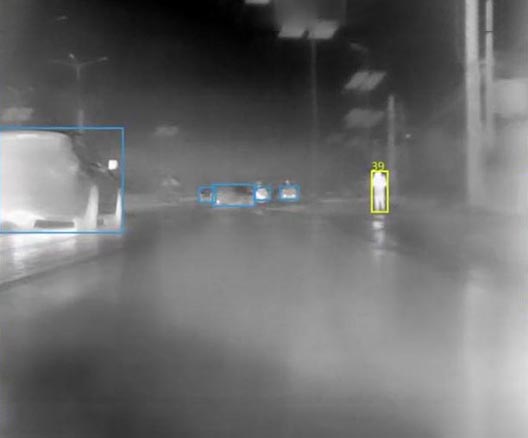
Building reliable perception across changing conditions requires more than meeting a defined test. It requires sensing and perception technologies designed for the environments vehicles encounter. SYLUX combines infrared sensing cameras with AI-powered perception to complement the traditional sensor stack and extend vehicle awareness for next-generation ADAS.